Highlight:
8LSA35.EB060D000-3 Servo Motor 1.6Nm 6000rpm No Brake
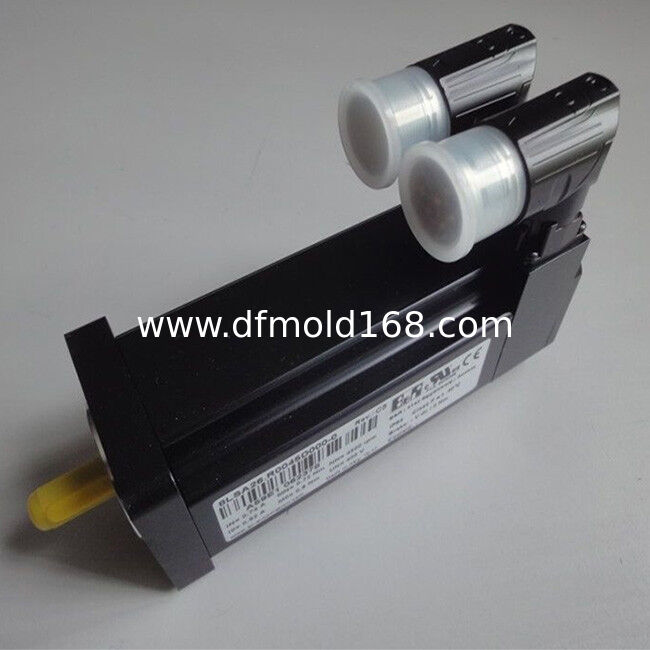
The 8LSA35.EB060D000-3 is a 1005 W synchronous servo motor developed for high-speed positioning, indexing and continuous motion applications that do not require an integrated holding brake.
It delivers a nominal torque of 1.6 Nm at 6000 rpm, a stall torque of 2.3 Nm and a maximum torque of 9.2 Nm. The maximum permitted motor speed is 9000 rpm, providing additional speed capacity during short dynamic movements.
The distinguishing feature of this configuration is its brake-free mechanical design. Compared with the corresponding brake-equipped version, it avoids the additional brake mass and brake inertia. This makes it suitable for horizontal axes, conveyors, rotary indexing mechanisms and other installations where an external holding device is unnecessary.
An inductive EnDat 2.1 multi-turn encoder provides absolute position feedback across multiple revolutions. This supports reliable restart positioning when the motor is used with a compatible drive, cable system and correctly configured machine parameters.
The motor has a smooth output shaft and an angled swivel connector. The adjustable connector direction helps simplify cable routing in compact machine frames and crowded control installations.
Key Differentiating Features
- Brake-free configuration for axes that do not require position holding
- 1.6 Nm nominal torque at 6000 rpm
- 9.2 Nm maximum torque for dynamic acceleration
- Maximum operating speed of 9000 rpm
- 1005 W nominal mechanical output
- EnDat 2.1 inductive multi-turn position feedback
- Smooth output shaft
- Angled swivel connector
- Four-pole-pair motor design
- Approximately 4.4 kg without added brake mass
- Suitable for replacement and machine maintenance projects
Why Choose the No-Brake Version?
The 8LSA35.EB060D000-3 should be selected when the driven mechanism does not need the motor shaft to remain mechanically locked after the drive is disabled.
Removing the integrated brake avoids approximately 1.09 kg of additional brake mass and 0.38 kg·cm² of brake inertia compared with the corresponding brake-equipped configuration.
This can be beneficial for rapidly reversing horizontal axes and rotary systems where lower moving mass and responsive acceleration are more important than power-off shaft holding.
For vertical or gravity-loaded axes, confirm whether an external holding mechanism is required before selecting the no-brake version.
Encoder and Position Feedback
The inductive EnDat 2.1 multi-turn encoder retains multi-revolution position information for compatible motion-control applications.
This configuration is particularly useful in machines where the controller must restore the mechanical position after shutdown without performing a complete reference movement.
Encoder compatibility must be checked against the installed servo drive, feedback cable and machine software. A motor with a different encoder code should not be treated as a direct replacement based only on frame size or output power.
Typical Applications
- High-speed packaging machinery
- Horizontal positioning axes
- Printing and converting equipment
- Rotary indexing tables
- Conveyor positioning systems
- Pick-and-place mechanisms
- Assembly machinery
- Material handling equipment
- Automated inspection systems
- Replacement of an existing matching motor
Installation and Replacement Notes
This motor must be operated through a compatible servo drive and must not be connected directly to a standard AC power supply.
Before replacement, verify the complete material number, encoder type, shaft design, connector arrangement, motor cable, feedback cable and drive parameter set.
The smooth shaft must match the installed coupling or clamping hub. A keyed-shaft motor is mechanically different and should not be substituted without checking the transmission design.
Confirm that the machine does not rely on an integrated holding brake. If the existing axis must remain stationary when drive power is removed, the brake-equipped D200 configuration may be required.
Frequently Asked Questions
1. Does 8LSA35.EB060D000-3 include a holding brake?
No. This is the no-brake configuration.
2. What is its nominal output?
The motor has a nominal output of 1005 W, a nominal torque of 1.6 Nm and a nominal speed of 6000 rpm.
3. What is the maximum motor speed?
The specified maximum speed is 9000 rpm.
4. What type of encoder is installed?
It uses an inductive EnDat 2.1 multi-turn encoder.
5. What is the difference between D000 and D200?
D000 has no holding brake. D200 includes a holding brake with a specified holding torque of 4 Nm.
6. Is it suitable for a vertical axis?
It can only be selected after confirming how the vertical load is held when the drive is disabled. An external holding mechanism or brake-equipped motor may be required.
7. Does it have a keyed shaft?
No. This material number specifies a smooth shaft.
8. Can it directly replace another 6000 rpm motor?
Not based on speed alone. Verify the full material number, encoder, shaft, connectors, cables, mounting dimensions and servo-drive parameters.

 Your message must be between 20-3,000 characters!